Nous
Hermes
Hermes
Marketplace
Community
Portal
Install Hermes
Install Hermes
Nous
Hermes
Community
Portal
Install Hermes
Install Hermes
All plugins
jamesEmerson112
GitHub profile
1 plugin in the catalog
Plugins by jamesEmerson112
1 plugins by jamesEmerson112 in the catalog, most-starred first.
jamesEmerson112
so101-arm
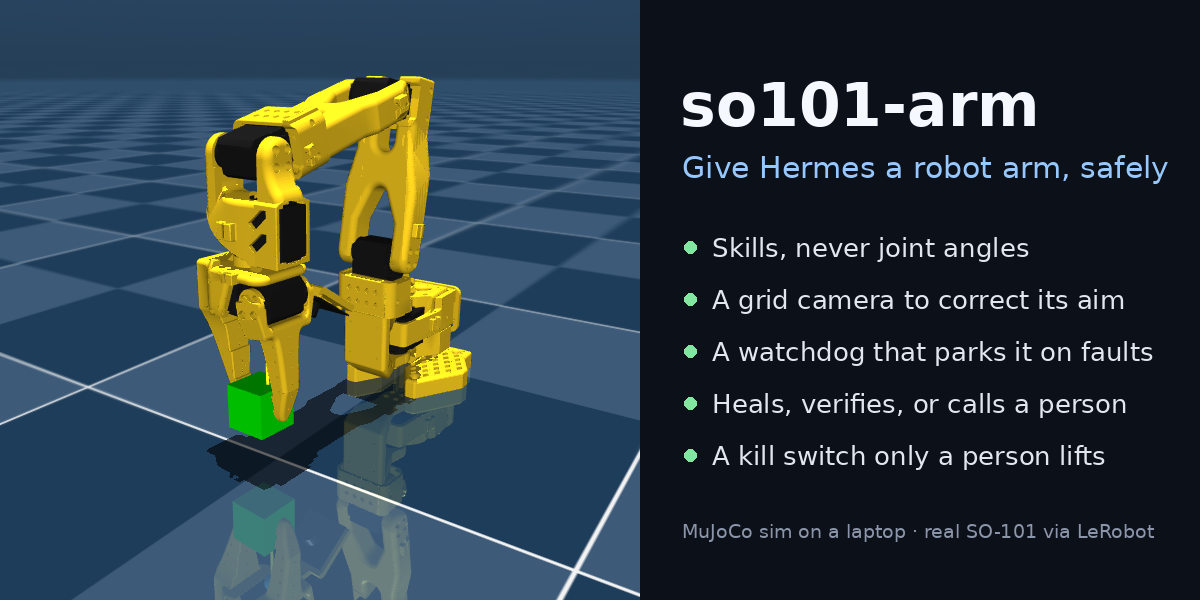
Give Hermes a robot arm, safely: an SO-101 (a MuJoCo sim on your laptop, or a real arm through LeRobot) driven by named skills, never joint angles. A top-down camera grid corrects its aim, a missed pick is rehearsed on simulated copies before the retry, a plain-code watchdog parks the arm on faults, a pre_tool_call guard refuses motion until a repair is verified, and only a person can lift a freeze (/arm unfreeze). Disclosure — the tools move a robot arm with no Hermes approval prompt: with the arm host started as serve --real, the agent drives a physical SO-101 over USB serial, limited to taught poses and motions, ±40 mm aim corrections and no more than the recorded speed (the default serve is a MuJoCo sim). The plugin talks only to a local Unix socket (mode 0600, default <temp dir>/so101-arm.sock) served by an arm host you start yourself (python -m so101_host serve). Any program running as you, Hermes's terminal tool included, can send that socket any command, unfreeze included, and the motion guard lets calls through when the host is down. Its log hooks send tool names, results and token counts (never conversation text) to that socket for the viewer. The arm host is a separate program from the same repository: it writes run records and camera frames under ~/.so101-arm/, fetch-model runs git to download MuJoCo Menagerie's SO-101 model at a pinned commit, and serve --video runs ffmpeg.
Community
tools
 GitHub profile