Nous
Hermes
Hermes
Marketplace
Community
Portal
Install Hermes
Install Hermes
Nous
Hermes
Community
Portal
Install Hermes
Install Hermes
All plugins
devorun
GitHub profile
1 plugin in the catalog
Plugins by devorun
1 plugins by devorun in the catalog, most-starred first.
devorun
talaria-bench
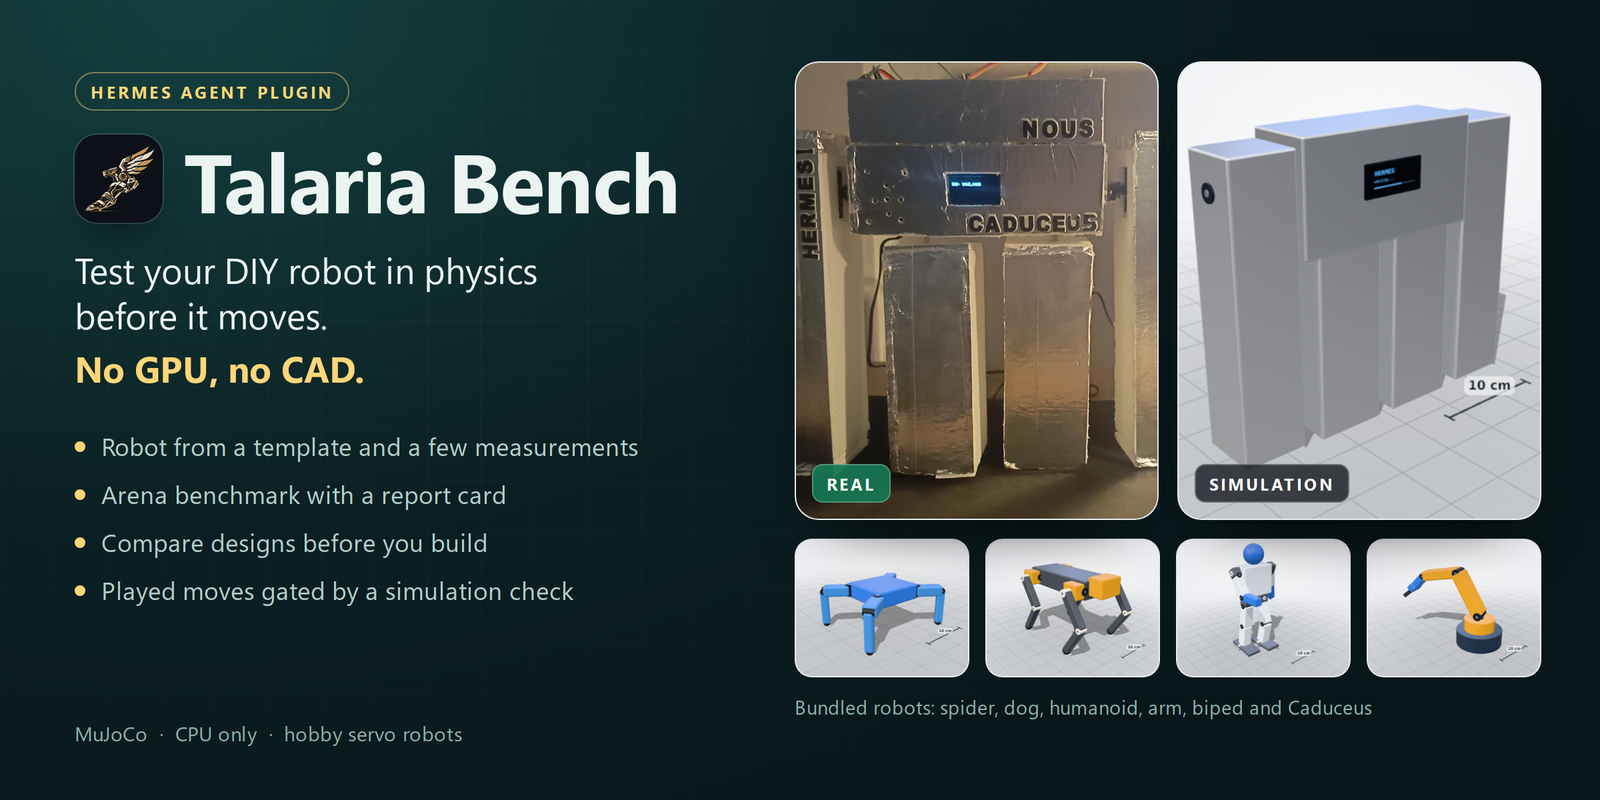
A physics test bench for DIY servo robots: build your robot from a template and a few measurements, see it in 3D next to its photo, run a one-click MuJoCo arena (flat, ramps, bars, pushes, slippery floor) across randomized worlds with a report card that says why it fails, compare design variants or watch a changed version side by side in the Arena, and gate robot_play / robot_pose with an exact-motion preflight in simulation before a move may play on the real robot (ESP32 + PCA9685 firmware included, or a virtual robot). CPU only, no GPU, no CAD. Disclosure — the automatic return to home (before a move and on robot_stop) is speed-limited (at least 3 s) but not simulated on its own; runs benchmark and comparison jobs as background Python subprocesses with worker pools (up to N-1 cores each, at most 2 jobs at once); starts local virtual-robot HTTP servers on 127.0.0.1 (random port, no token) on demand, and `hermes talaria sim` listens on 127.0.0.1:8765 unless --host is given; sends plain HTTP only to the robot address you set (bypassing proxies; the robot token travels unencrypted on your LAN); reads a robot photo only from a path you give under your home or Hermes folder; writes robots, photos, moves, approvals, jobs, reports and caches under $HERMES_HOME/plugin-data/talaria-bench (the trace cache is not pruned). The optional robot token is a Hermes secret. No third-party services, shell commands, downloads or telemetry.
Community
tools
 GitHub profile